Mohammad
Robot Learning Researcher

Hello, I’m Mohammad, a Ph.D. candidate in Computer Science at George Mason University, working in the RobotiXX lab.
Research Goal: I study how robots can learn to understand and act in the physical world with minimal human supervision. My work combines self-supervised learning from multiple sensor modalities, learned models of how the world responds to a robot’s actions, and real-time planning with those models on real hardware. I’m especially interested in representations and world models that aren’t tied to a single task, so the same ideas can carry across robots, environments, and embodiments.
news
| Aug 29, 2026 | Hydra: A Navigation World Action Model with Discrete Latent Planning and Continuous Flow-Matching Execution introduces a unified world model and planner that can perform planning in latent space is on arXiv. |
|---|---|
| Jul 08, 2026 | HumAIN: Human-Aware Implicit Social Robot Navigation was accepted at IROS 2026. |
| Jun 30, 2026 | Received a $10,000 Microsoft Azure Compute Grant through the Microsoft Research Accelerator Program to support the Hydra project. |
| Jun 15, 2026 | Received the Best Student Presentation Award at the 1st Workshop on Long-term Deployments in the Wild (LoWi) at IEEE ICRA 2026 in Vienna, Austria, for the presentation of VertiFormer. |
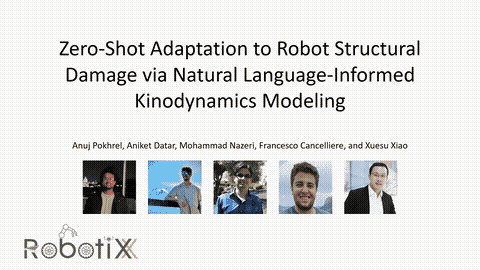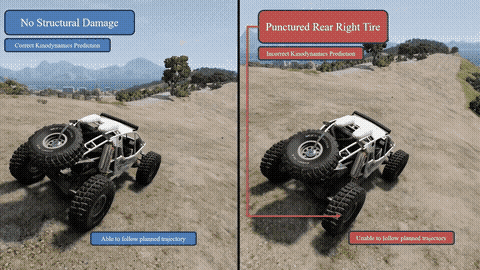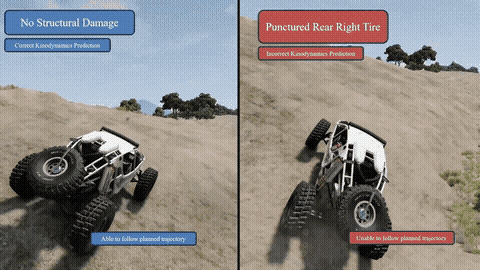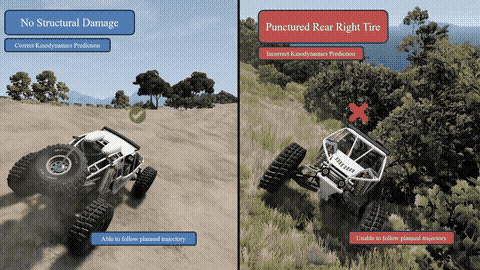
| Feb 12, 2026 | Zero-Shot Adaptation to Robot Structural Damage via Natural Language-Informed Kinodynamics Modeling introduces language-informed kinodynamics modeling for zero-shot adaptation to robot structural damage is on arXiv. |